Lecture 20
E21 Computer Engineering Fundamentals
November 12, 2026
Linear & Nonlinear Interpolation
Fitting a polynomial of degree \(n\) to a set of \(n+1\) points is an example of linear interpolation.
Interpolate the polynomial \[y = a_0 + a_1 x + a_2 x^2 + ... a_n x^n \] to the points \(\{ x_0, y_0 \}, \{ x_1, y_1 \}, \{ x_2, y_2 \}, ... , \{ x_n, y_n \}\) by solving an equation for the parameters \(\{ a_0, a_1, a_2, ..., a_n \}\)
\[
{\begin{bmatrix}
x_0^0 & x_0^1 & x_0^2 & \cdots & x_0^n \\
x_1^0 & x_1^1 & x_1^2 & \cdots & x_1^n \\
\vdots & \vdots & \vdots & \ddots & \vdots \\
x_n^0 & x_n^1 & x_n^2 & \cdots & x_n^n
\end{bmatrix}}
\begin{bmatrix}
a_0 \\
a_1 \\
\vdots \\
a_n
\end{bmatrix}
=
\begin{bmatrix}
y_0 \\
y_1 \\
\vdots \\
y_n
\end{bmatrix}
\]
What’s nonlinear interpolation ?
Nonlinear interpolation is when the interpolating function depends nonlinearly on the looked-for parameters.
An example of nonlinear interpolation
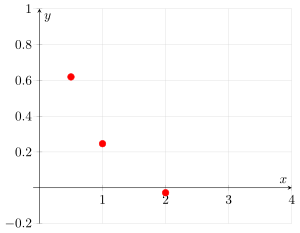
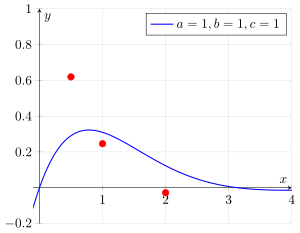
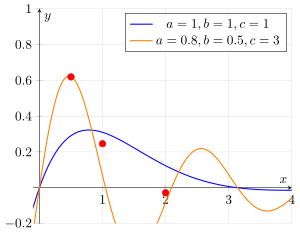
Interpolate the points \(\{ 0.5, 0.6191\}, \{ 1, 0.24612\}, \{ 2, -0.0277\}\) to the curve \(\boxed{y(x) = a e^{-b x} \sin (c x)}\).
Write down the mathematical equations for this problem.
Equations for nonlinear interpolation
Interpolating \(\{ 0.5, 0.6191\}, \{ 1.0, 0.24612\}, \{ 2.0, -0.0277\}\) to \(\boxed{y(x) = a e^{-b x} \sin (c x)}\)
requires solving three equations for three unknowns
\[
\begin{align*}
\phantom{-}0.6191 &= a e^{-b \times 0.5} \sin (c \times 0.5) \\
\phantom{-}0.2461 &= a e^{-b \times 1.0} \sin (c \times 1.0) \\
-0.0277 &= a e^{-b \times 2.0} \sin (c \times 2.0)
\end{align*}
\]
Notice that the interpolating function \(y(x)\) depends nonlinearly on the parameters \(b\) and \(c\).
i.e., an equation of this kind does not exist:
\[
{\begin{bmatrix}
A_{11} & A_{12} & A_{13} \\
A_{21} & A_{22} & A_{23} \\
A_{31} & A_{32} & A_{33}
\end{bmatrix}}
\begin{bmatrix}
a \\
b \\
c
\end{bmatrix}
=
\begin{bmatrix}
d_1 \\
d_2 \\
d_3
\end{bmatrix}
\]
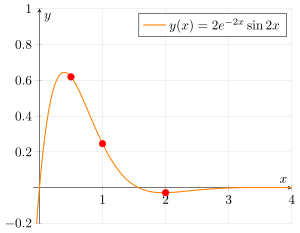
Successful Interpolation with other-than-polynomial functions
![]()
- The function \(y(x) = 2 e^{-2x} \sin 2x\) happens to pass through all three given points exactly.
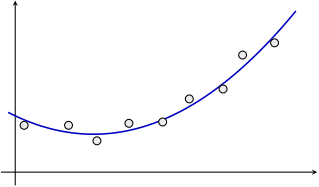
The need for Curve Fitting
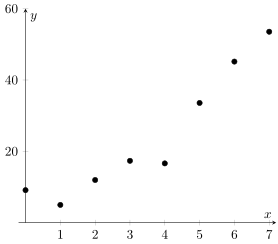
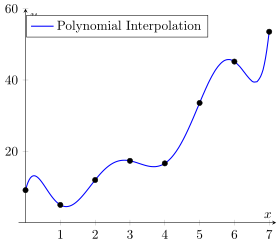
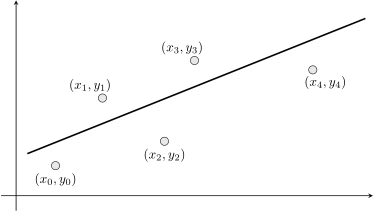
Consider the following data points and make
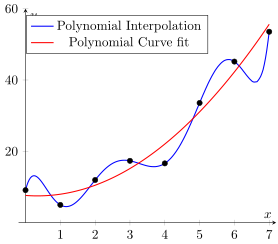
- Polynomial interpolation follows the given data exactly
- But practically, we sometimes just want the trend
- Curve fits are a mathematically-determined ‘curve of best fit’
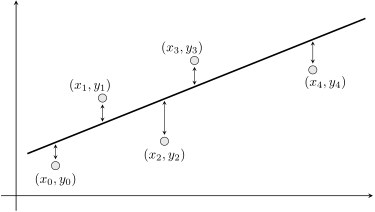
Line of best fit
Goal: Find a straight line that is as close as possible to the data points
- Draw any straight line with equation \(y = f(x)\)
- Measure the components of a ‘residual vector’ \(r_i = y_i - f(x_i)\)
- vertical distance between a point and the line of best fit
- Adjust the line until the norm of the residual vector is the smallest it will ever be.
Goal: Find \(f(x) = a_0 + a_1 x\) such that \(\sum r_i^2\) is minimized.
“Minimize the sum of the squares of the residuals”
Least Squares Fit
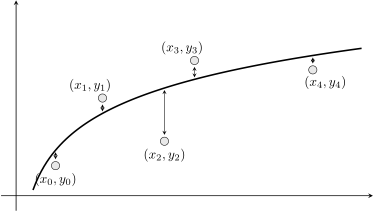
- A ‘least squares fit’ is much more general than straight lines or even polynomials.
- Potentially, any function can be fit to given data by minimizing the sum of the squares of the residuals
Linear vs. nonlinear least squares
- Consider some functions \(f(x)\) that depend also on some parameters \(\{ a_0, a_1, a_2, ... \}\):
- \(f(x) = a_0 + a_1 \sin x\)
- \(f(x) = a_0 x - \log x\)
- \(f(x) = a_0 x - \log a_1 x\)
- \(f(x) = a_0 x + a_1 \log x\)
- \(f(x) = a_0 x + a_1 x^3 - a_2 x^5\)
- \(f(x) = a_0 \sin (a_1 x) + a_2\)
Which of these is linear in the parameters \(a_i\) and which is nonlinear in the parameters \(a_i\) ?
Linear vs. nonlinear least squares
Linear Least Squares
Function \(f(x)\) depends linearly on the parameters \(\{ a_0, a_1, a_2, ... \}\)
Nonlinear Least Squares
Function \(f(x)\) depends nonlinearly on at least one of the parameters \(\{ a_0, a_1, a_2, ... \}\)
- In both cases, \(f(x)\) is allowed to be nonlinear in \(x\).
Curve Fitting \(n\) data points to \(m\)-degree polynomial
Find the parameters \(\{ a_0, a_1, a_2, ..., a_m \}\) that minimize the so-called objective function \(\boxed{S = \sum_{i} [y_i - f(x_i)]^2}\),
where \(f(x) = a_0 + a_1 x + a_2 x^2 + ... + a_m x^m\)
Note: the summation symbol refers to ‘sum over all \(n\) points’
Idea: Take derivatives with respect to \(a_0\), \(a_1\), etc. and set them all to zero, to find \(\{ a_0, a_1, a_2, ... ,a_m \}\)
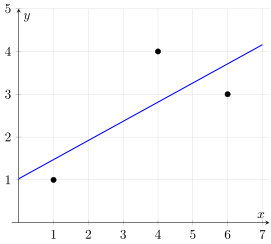
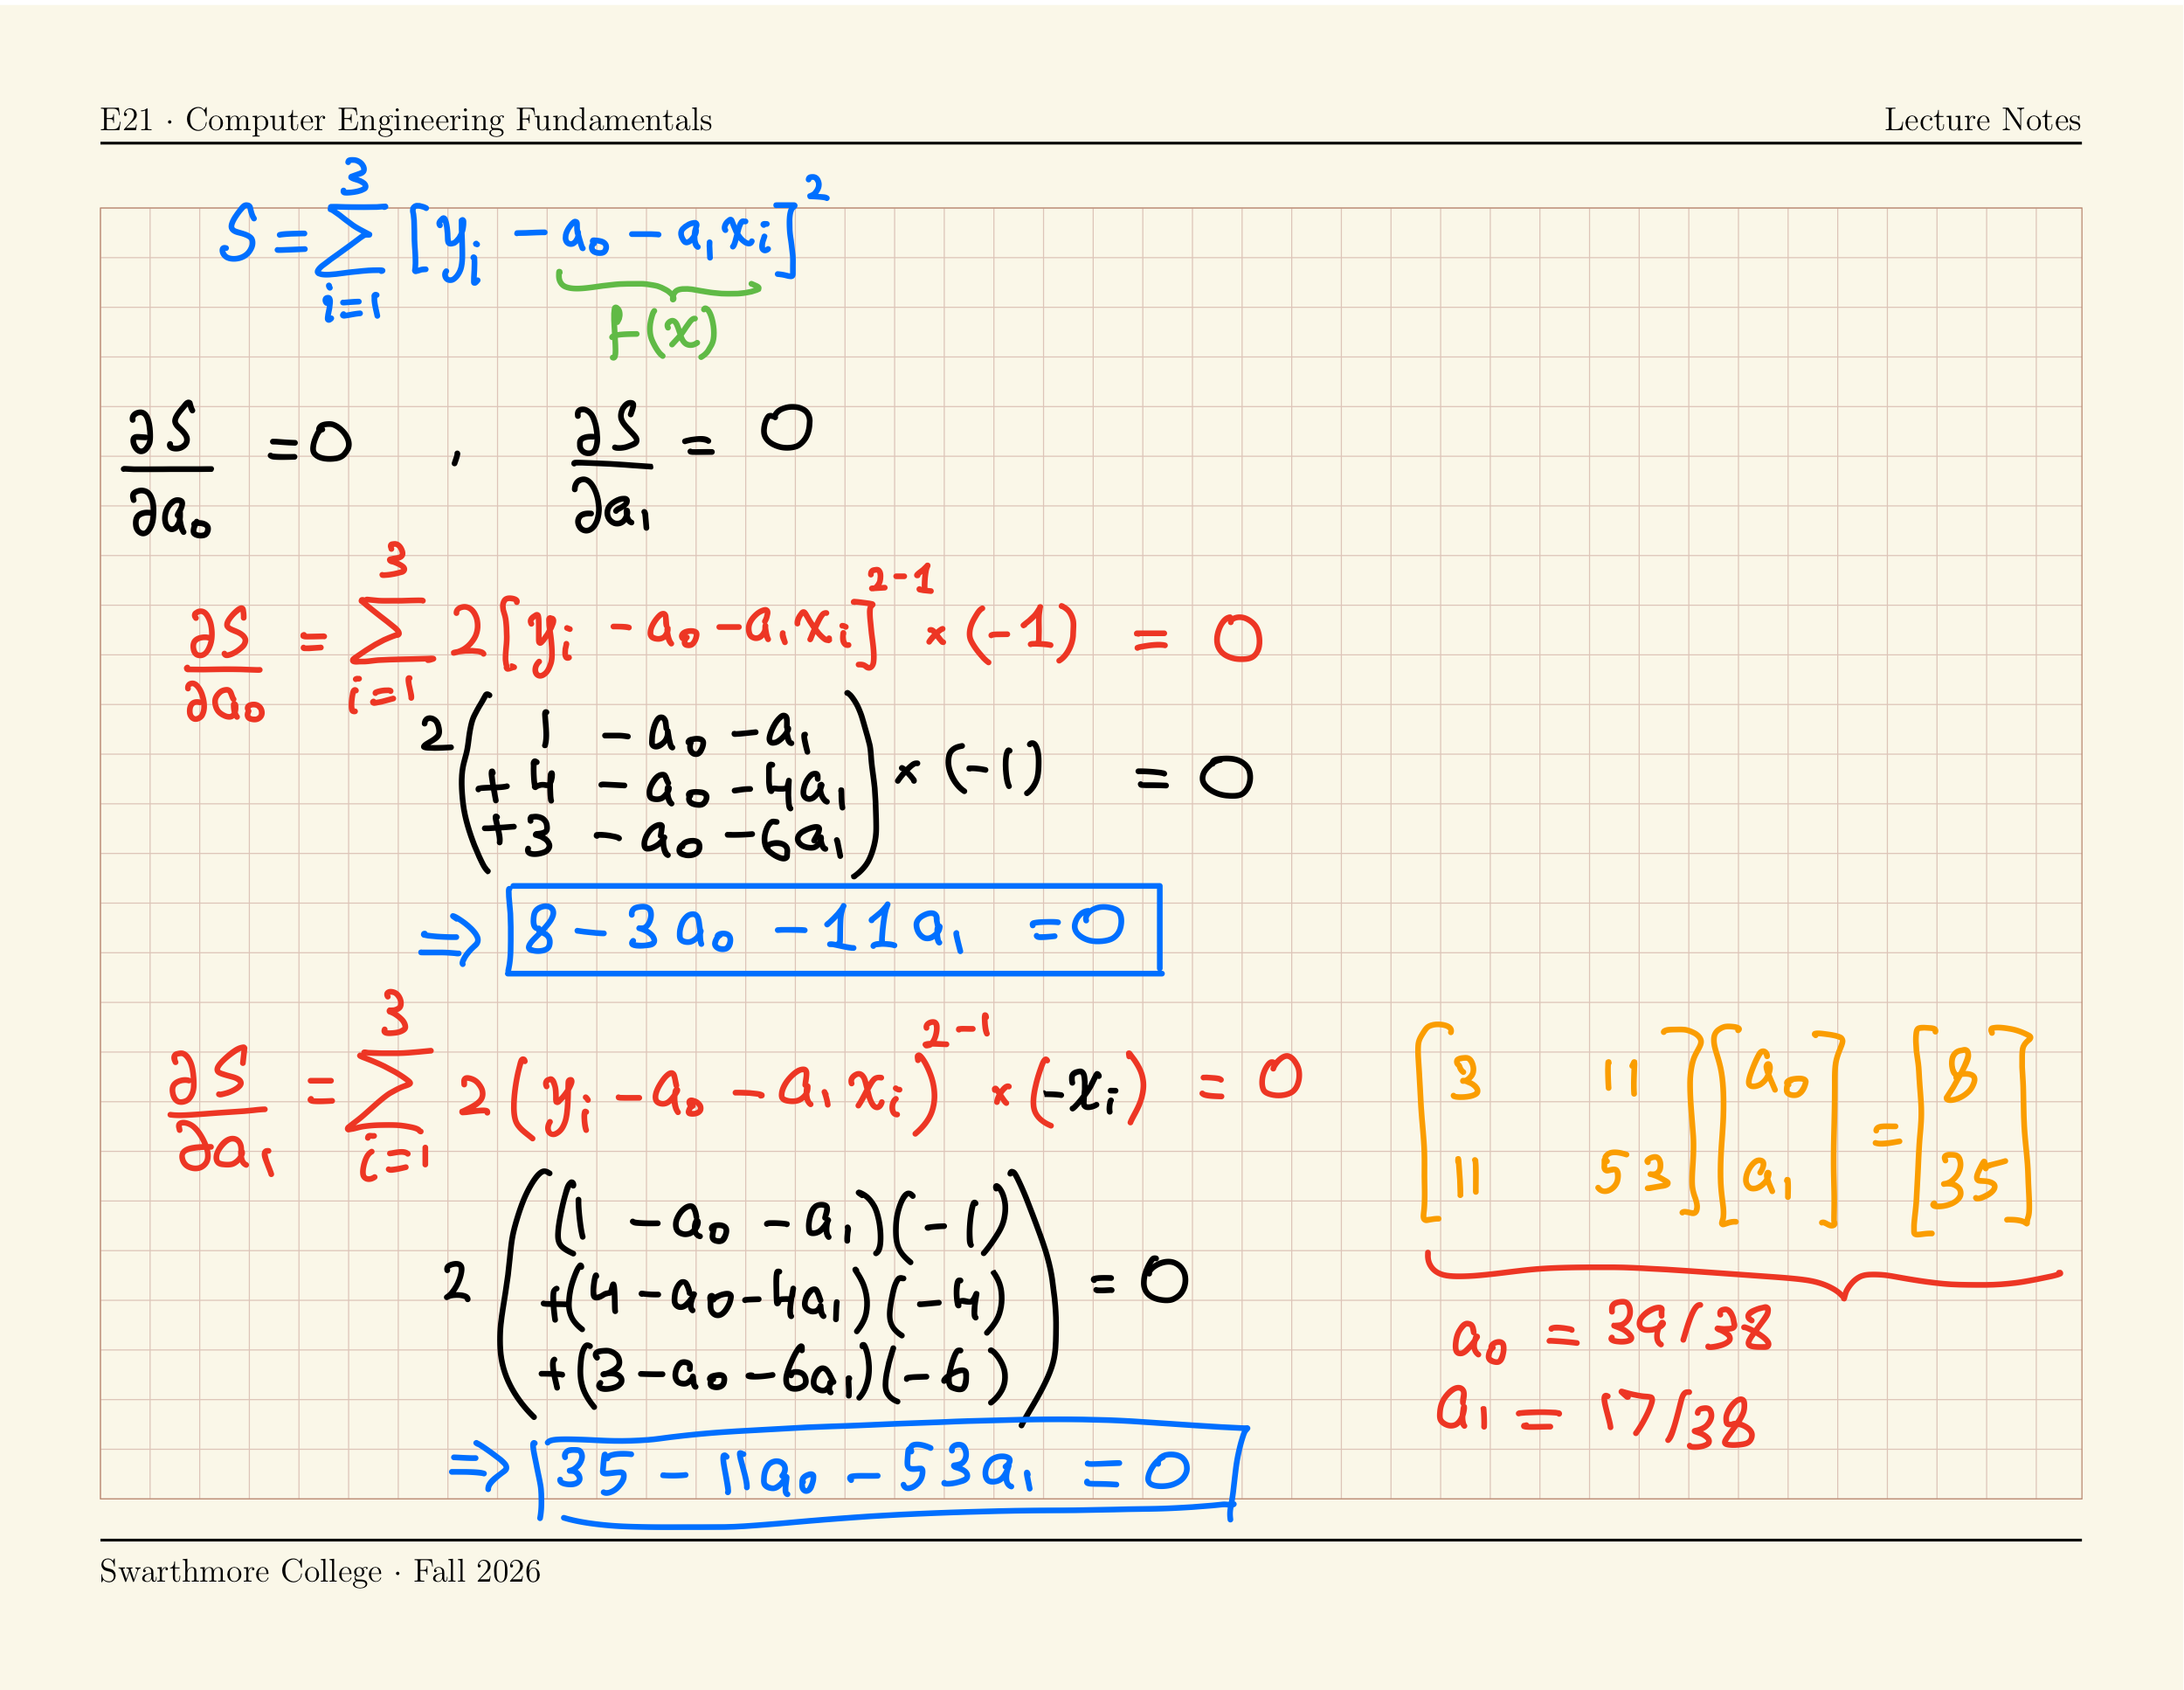
Example: a line of best fit for three points
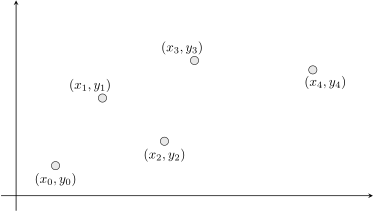
Find the equation of the straight line \(y = a_0 + a_1 x\) that passes through the three points shown while minimizing \(S\).
Hint: Write down two simultaneous equations for \(a_0\) and \(a_1\).
Solving by hand
![]()
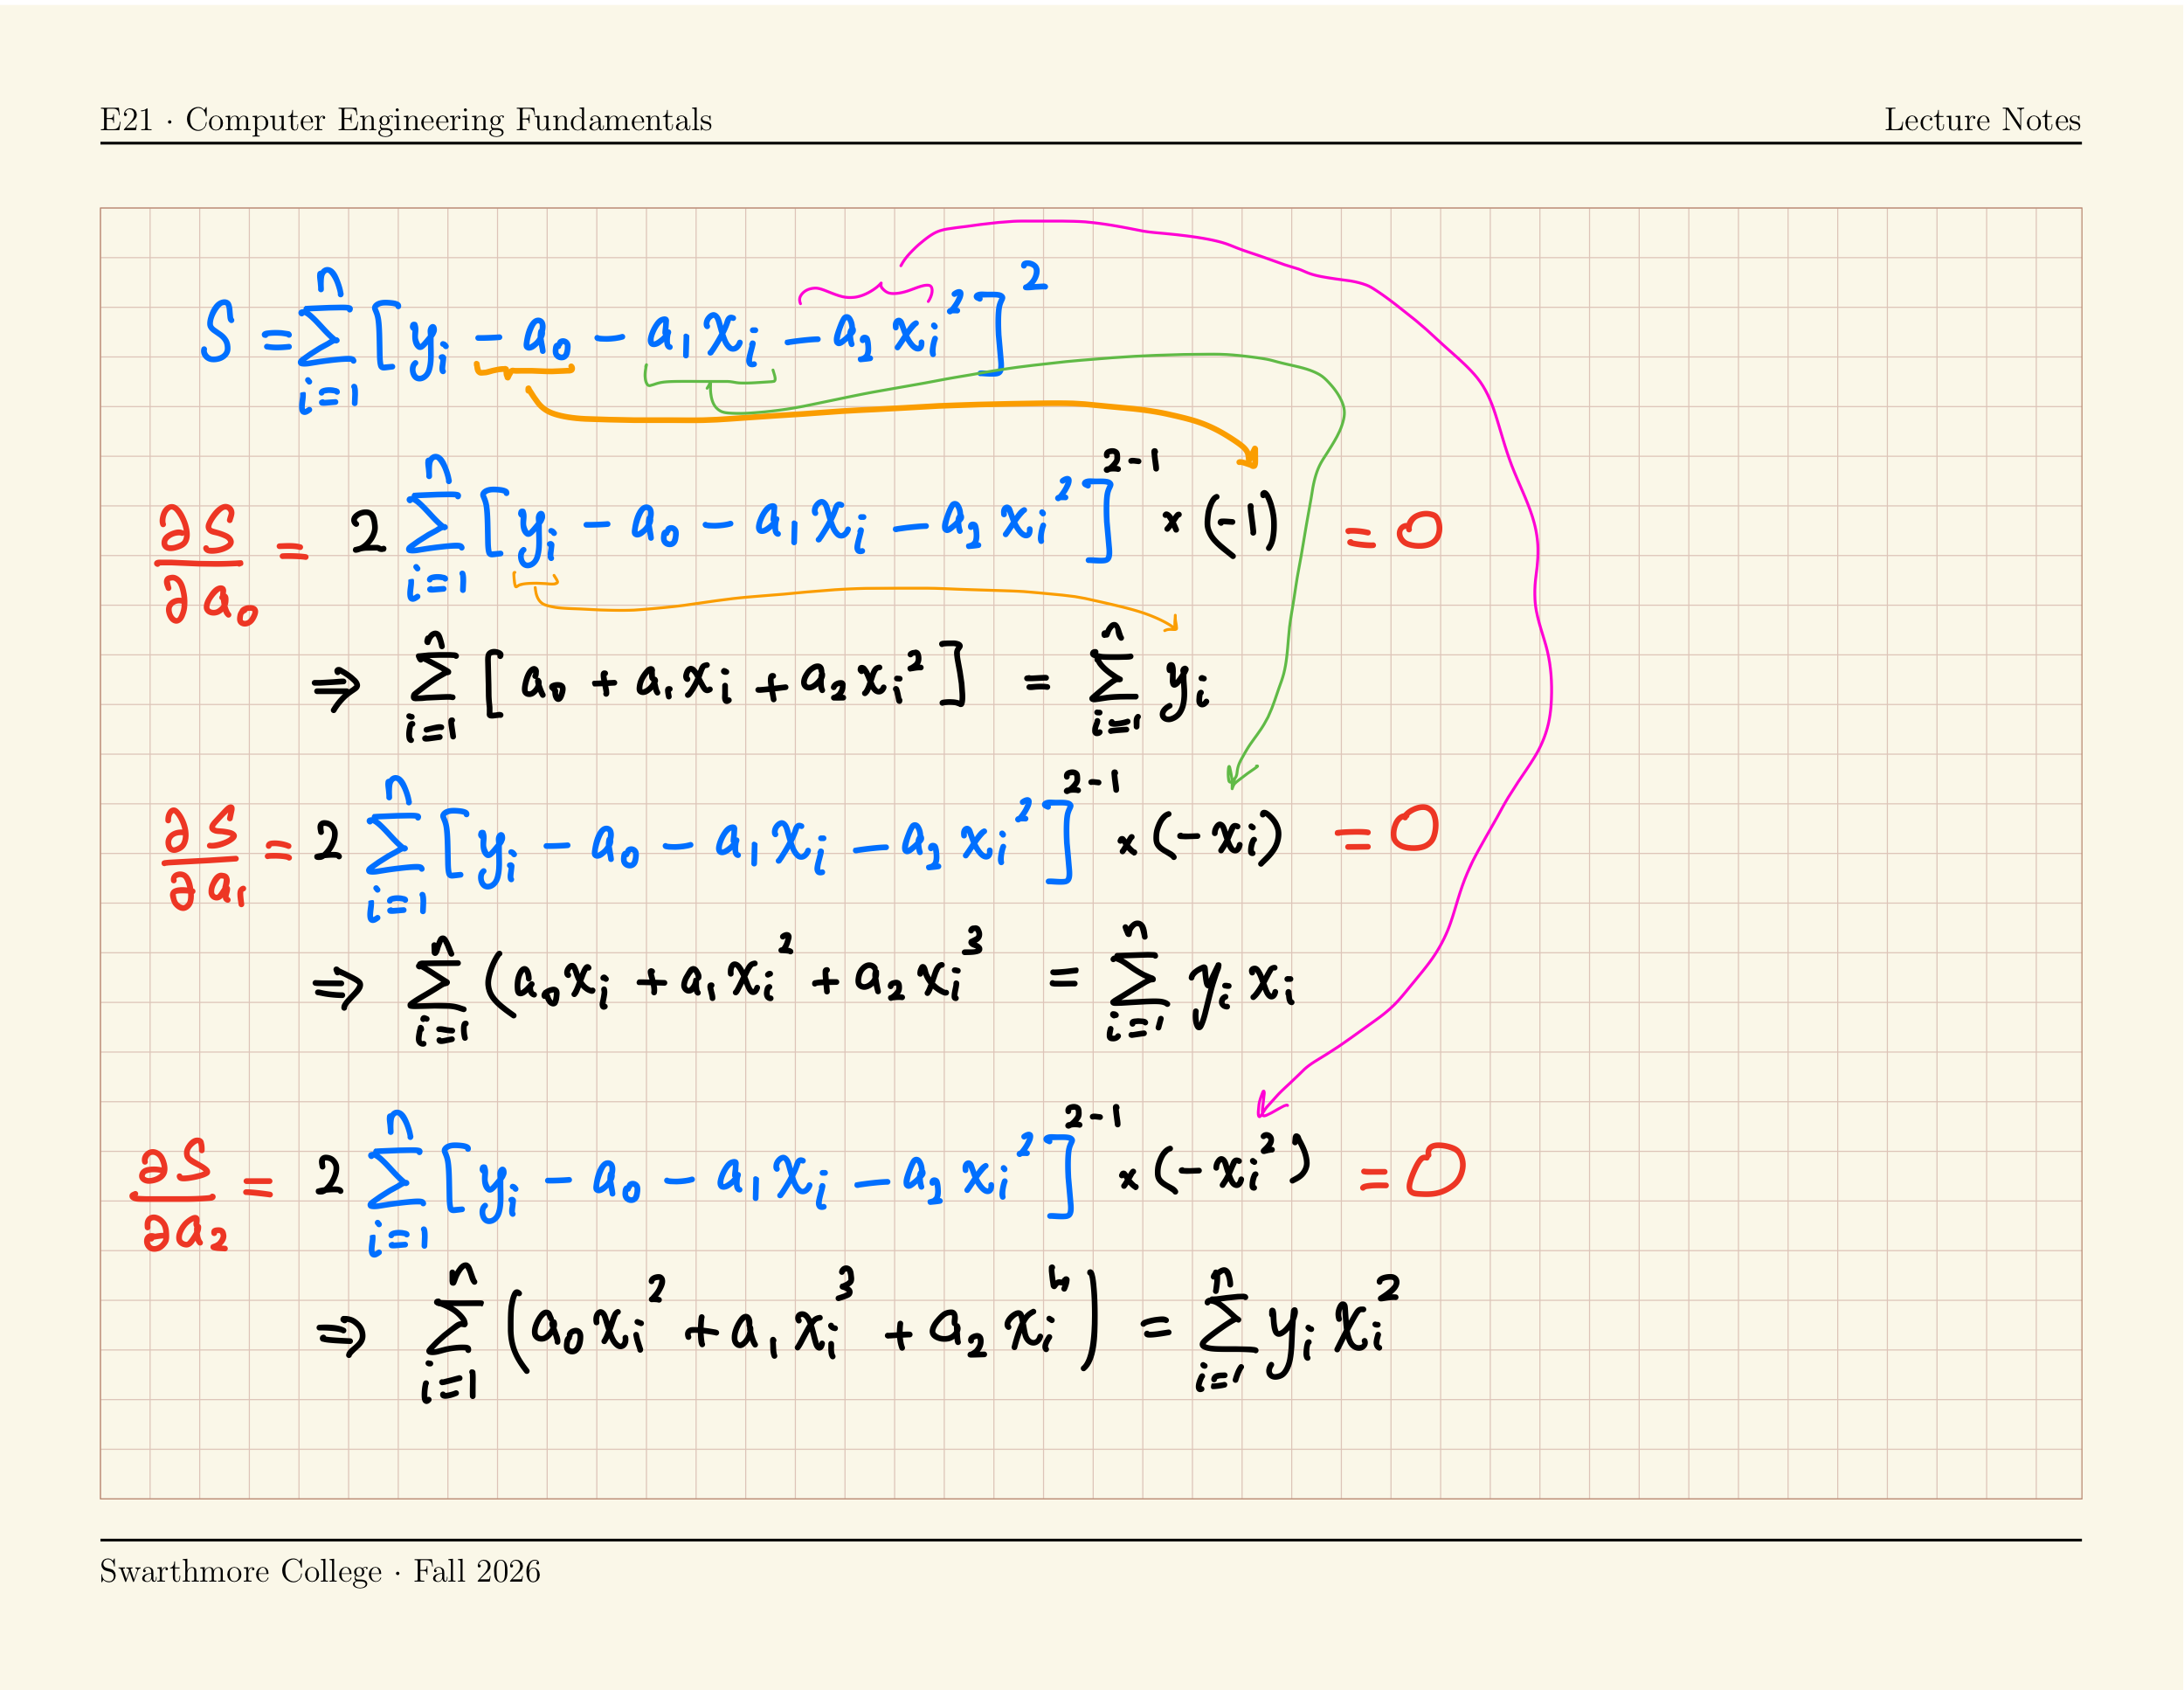
System of equations for fitting a quadratic polynomial (degree \(m=2\))
\[
\begin{aligned}
\sum_{i} \left( {\color{red}{a_0}}{\color{green}{x_i^0}} + {\color{red}{a_1}}{\color{green}{x_i^1}} + {\color{red}{a_2}}{\color{green}{x_i^2}} \right) &= \sum_{i} {\color{green}{y_i}}{\color{green}{x_i^0}} \\
\sum_{i} \left( {\color{red}{a_0}}{\color{green}{x_i^1}} + {\color{red}{a_1}}{\color{green}{x_i^2}} + {\color{red}{a_2}}{\color{green}{x_i^3}} \right) &= \sum_{i} {\color{green}{y_i}}{\color{green}{x_i^1}} \\
\sum_{i} \left( {\color{red}{a_0}}{\color{green}{x_i^2}} + {\color{red}{a_1}}{\color{green}{x_i^3}} + {\color{red}{a_2}}{\color{green}{x_i^4}} \right) &= \sum_{i} {\color{green}{y_i}}{\color{green}{x_i^2}}
\end{aligned}
\]
\[
\begin{bmatrix}
\sum x_i^0 & \sum x_i^1 & \sum x_i^2 \\
\sum x_i^1 & \sum x_i^2 & \sum x_i^3 \\
\sum x_i^2 & \sum x_i^3 & \sum x_i^4
\end{bmatrix}
\begin{bmatrix}
a_0 \\
a_1 \\
a_2
\end{bmatrix}
=
\begin{bmatrix}
\sum y_i x_i^0 \\
\sum y_i x_i^1 \\
\sum y_i x_i^2
\end{bmatrix}
\]
Note: all sums are carried out over the \(n\) data points.
System of equations for fitting a polynomial of degree \(m\) to a set of \(n\) data points
\[
\begin{bmatrix}
\sum x_i^0 & \sum x_i^1 & \sum x_i^2 & \cdots & \sum x_i^m \\
\sum x_i^1 & \sum x_i^2 & \sum x_i^3 & \cdots & \sum x_i^{m+1} \\
\sum x_i^2 & \sum x_i^3 & \sum x_i^4 & \cdots & \sum x_i^{m+2} \\
\vdots & \vdots & \vdots & \ddots & \vdots \\
\sum x_i^m & \sum x_i^{m+1} & \sum x_i^{m+2} & \cdots & \sum x_i^{m+m}
\end{bmatrix}
\begin{bmatrix}
a_0 \\
a_1 \\
a_2 \\
\vdots \\
a_m
\end{bmatrix}
=
\begin{bmatrix}
\sum x_i^0 y_i \\
\sum x_i^1 y_i \\
\sum x_i^2 y_i \\
\vdots \\
\sum x_i^m y_i
\end{bmatrix}
\]
Note: all sums are carried out over the \(n\) data points.
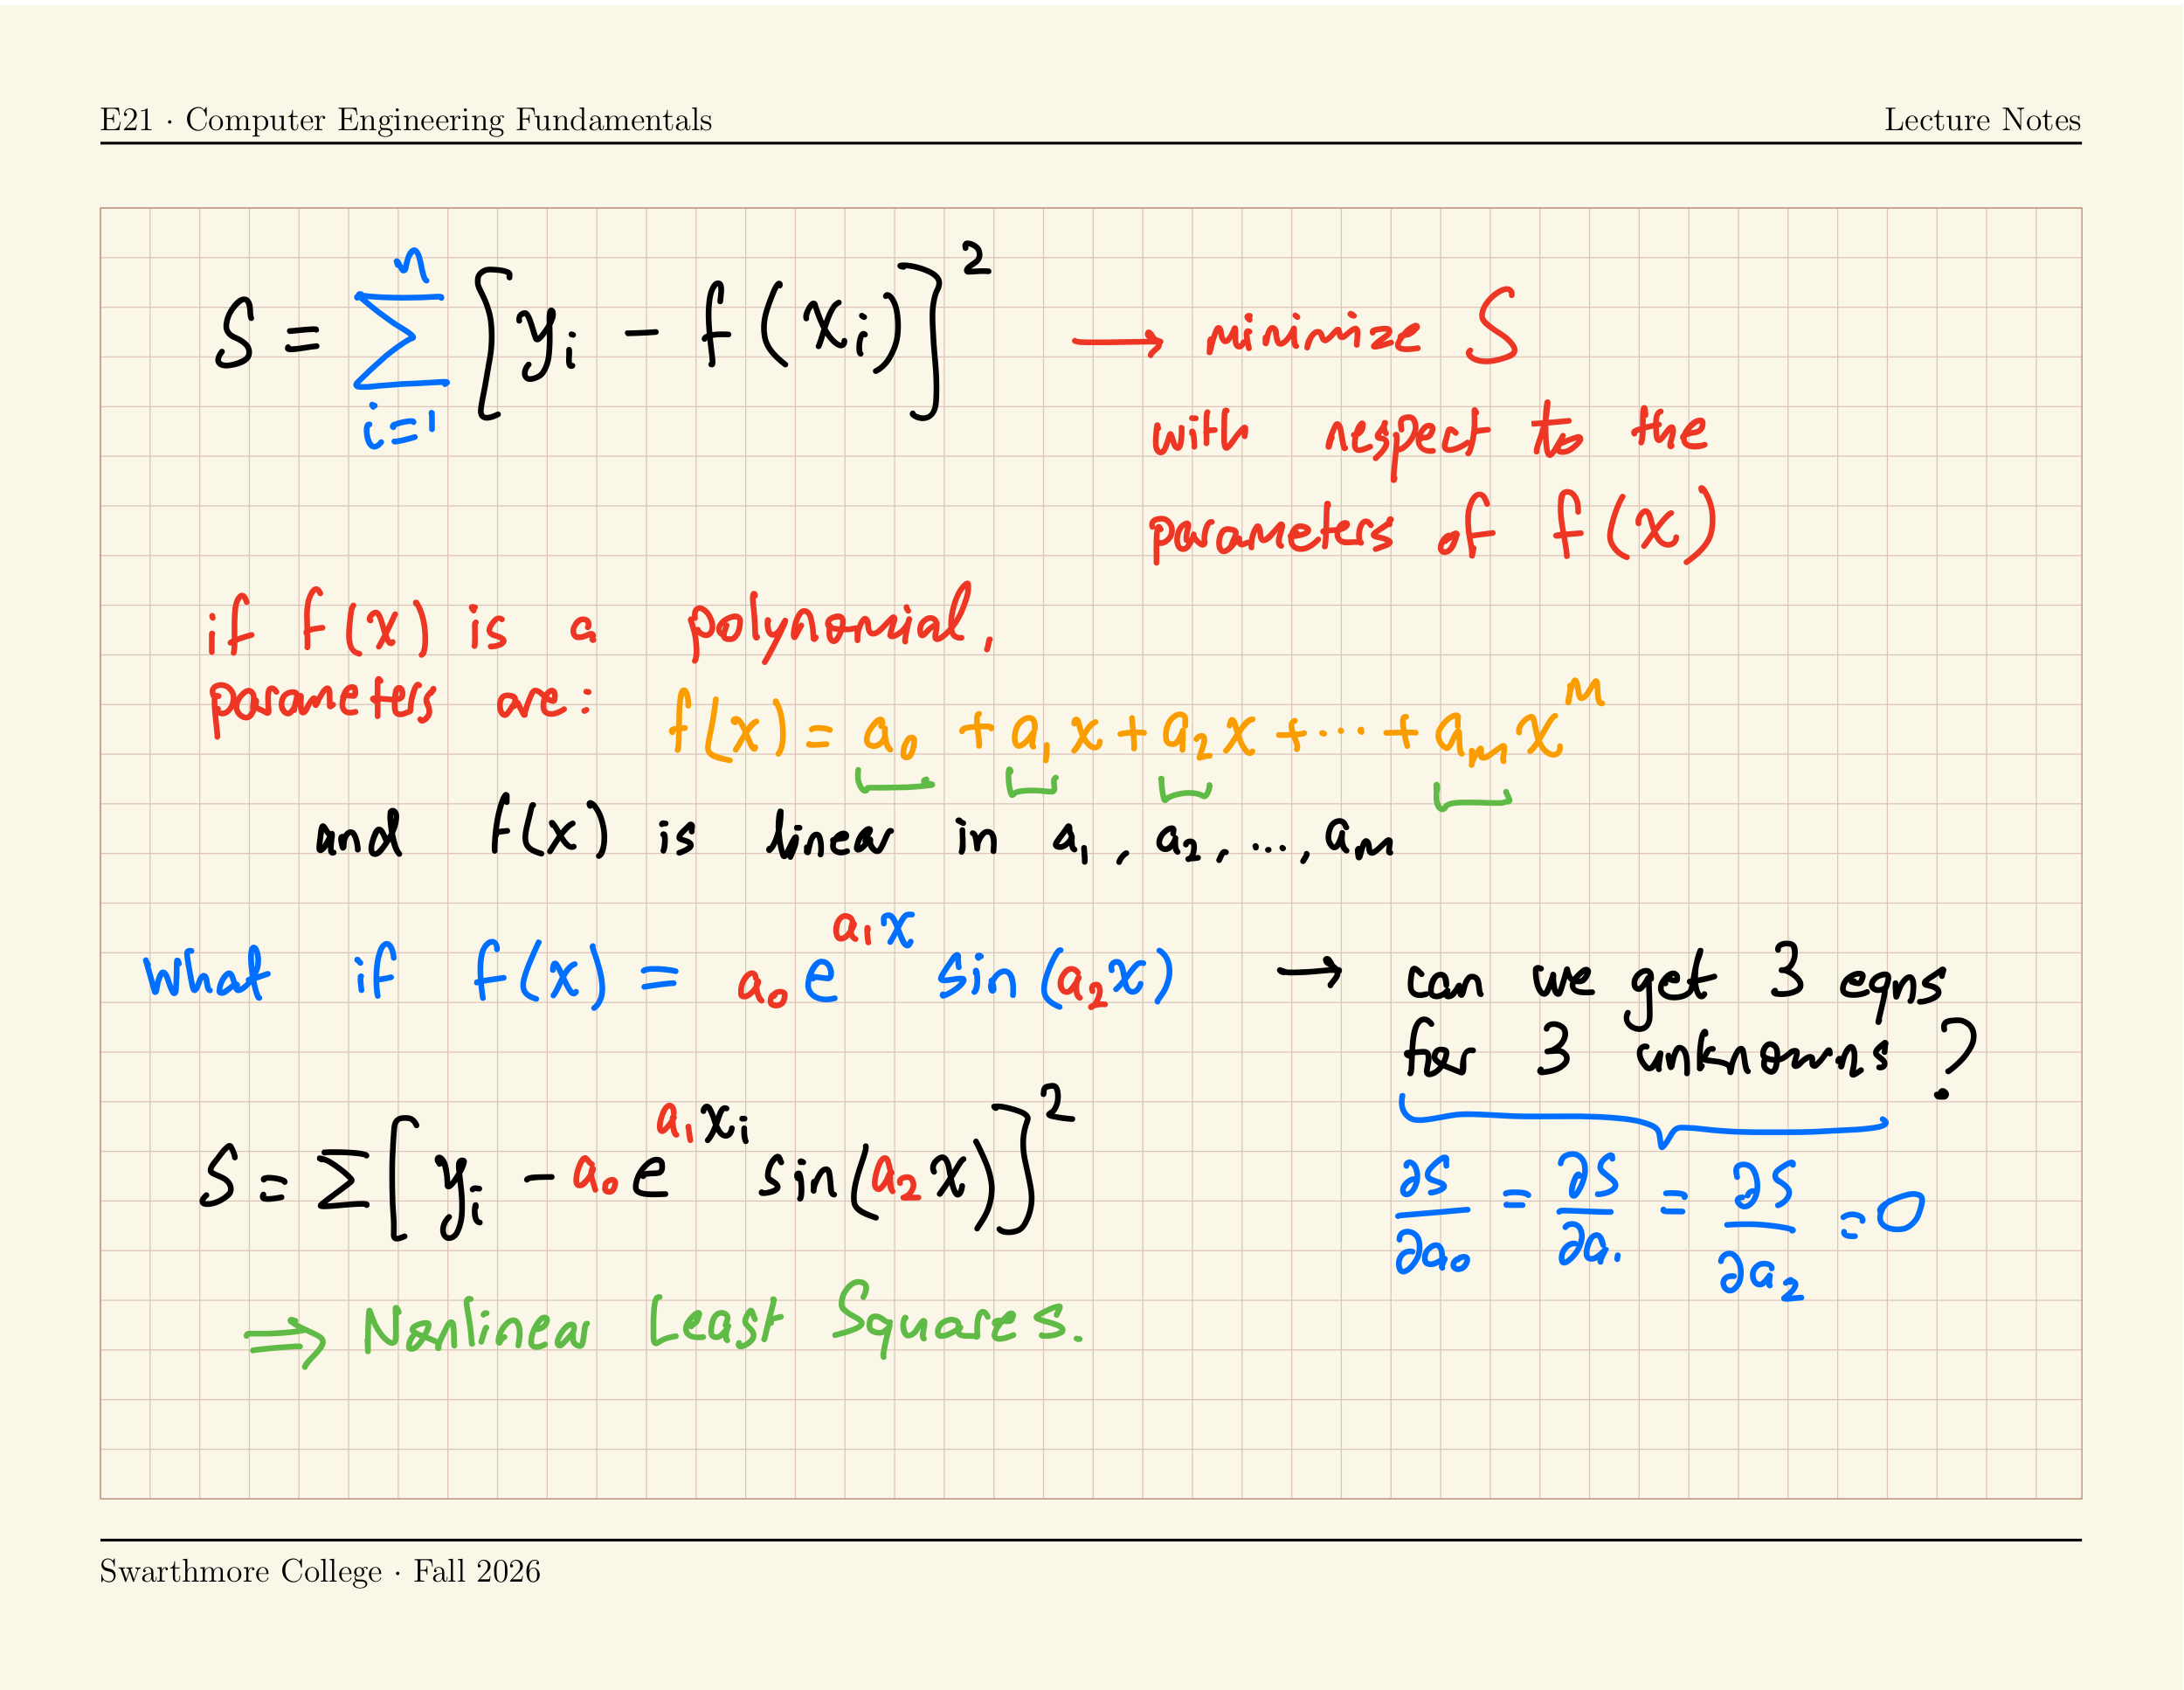
Nonlinear Least Squares
Where \(f(x)\) depends nonlinearly on at least one of the parameters \(a_0,a_1,...,a_m\)
![]()
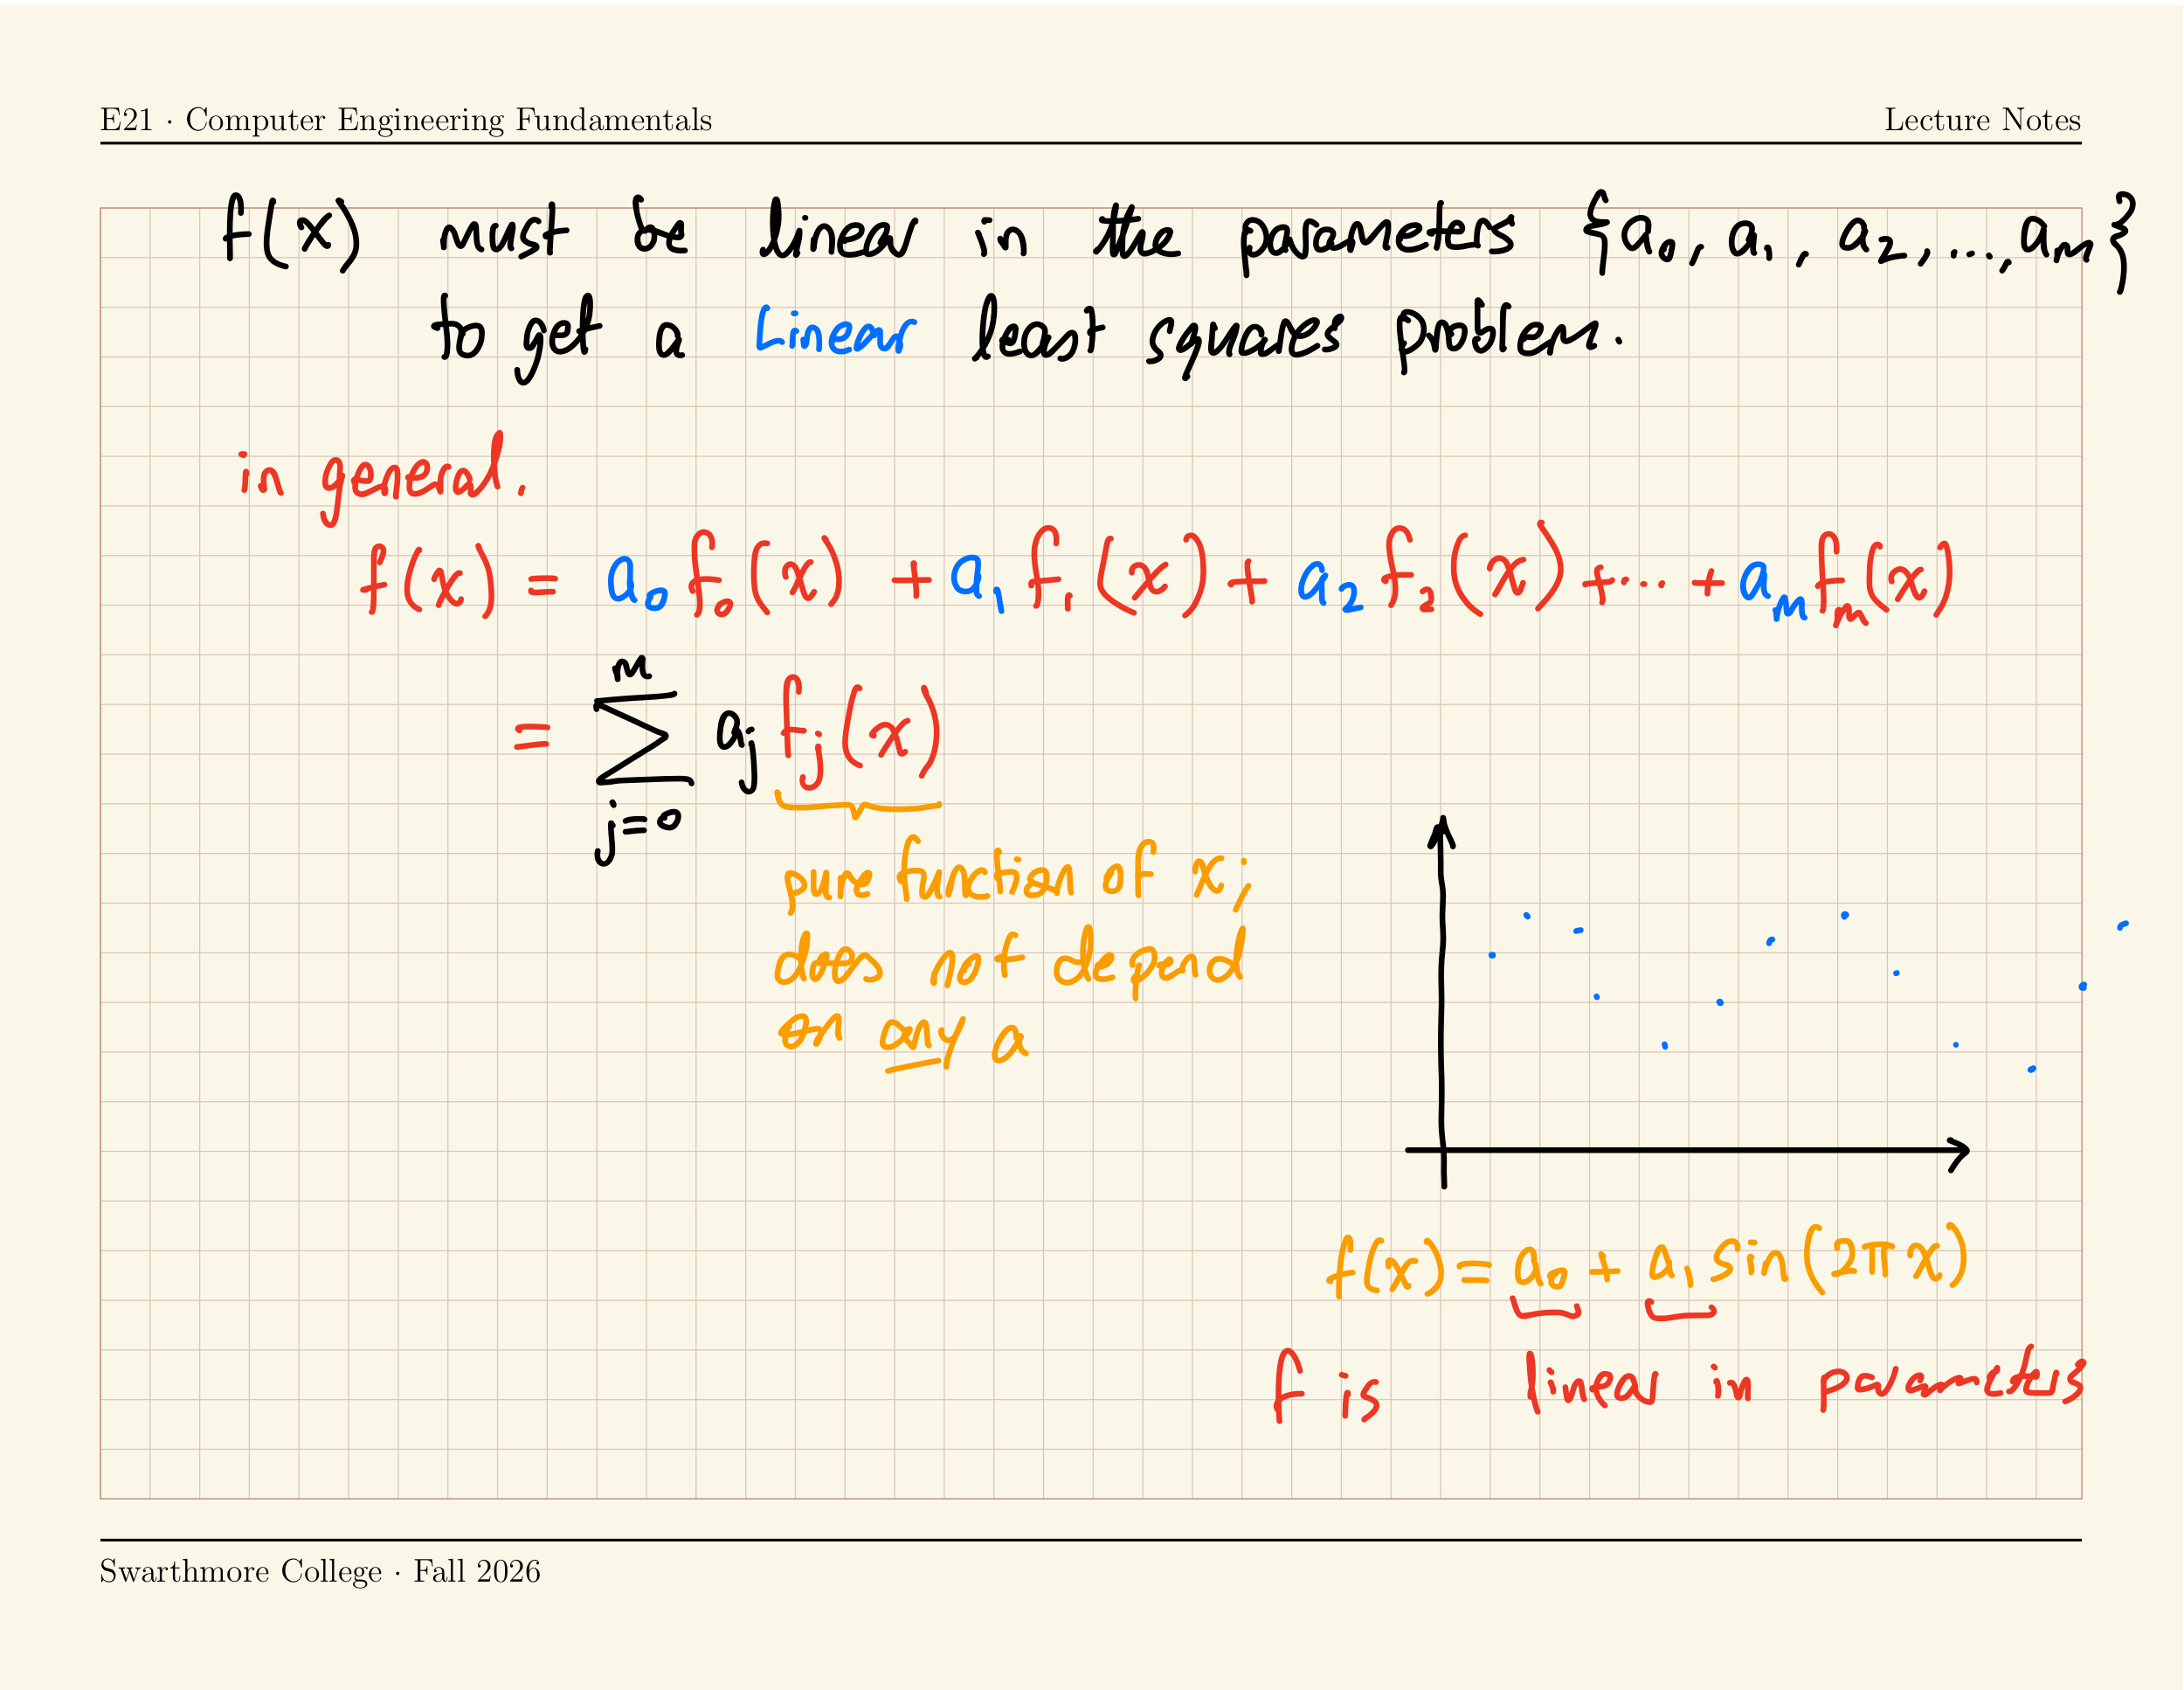
Linear Least Squares for functions other than polynomials
Where \(f(x)\) is a linear combination of \(m\) (possibly nonlinear) basis functions \(f_j(x)\)
![]()